SECURE: Secure Interaction-aware Multi-robot Cooperation
project image

People

Andrei-Carlo Papuc - PhD candidate
Prof. Laura Ferranti
Prof. Javier Alonso-Mora

Funding

This project is funded by the Office of Naval Research Global (ONRG).

About the Project

Autonomous mobile robots will provide fundamental help to humans in a variety of missions, such as area monitoring, surveillance, exploration, information gathering or construction of infrastructures, potentially in cooperation with robots from other organizations. The result of this cooperation will be a heterogeneous team of robots with different capabilities and interfaces, possibly working together with humans. Robots will have to communicate with each other and share sensitive information, which is not possible with currently available methods.

SECURE aims to resolve the conflicting objectives of safety, security, and privacy. For instance, modifying shared information for security purposes could compromise the safety of the robots. The proposed multi-robot coordination framework will feature several interconnected modules to ensure security and privacy while maintaining safety. By integrating control theory, robotics, and computer science, SECURE will develop an innovative interaction-aware framework for robots to navigate near other agents. This will be enhanced by an active-diagnosis strategy to detect and isolate malicious agents within the network. The project will also explore how to shape robot navigation constraints to account for communication delays and leverage robust control approaches to enhance network security and interaction safety.

The project will develop open-source algorithms and demonstrate their effectiveness using autonomous mobile robots like Micro Aerial Vehicles or mobile manipulators. The ultimate goal is to enable the safe and secure deployment of a team of mobile robots in unknown environments in cooperation with other parties.

Funding & Partners

This project is funded by the Office of Naval Research Global (ONRG).


Language-Driven Cost Optimization for Autonomous Driving
Diego Martinez-Baselga, Khaled A. Mustafa, Javier Alonso-Mora. In IEEE Intelligent Transportation Systems Conference (ITSC), 2026.
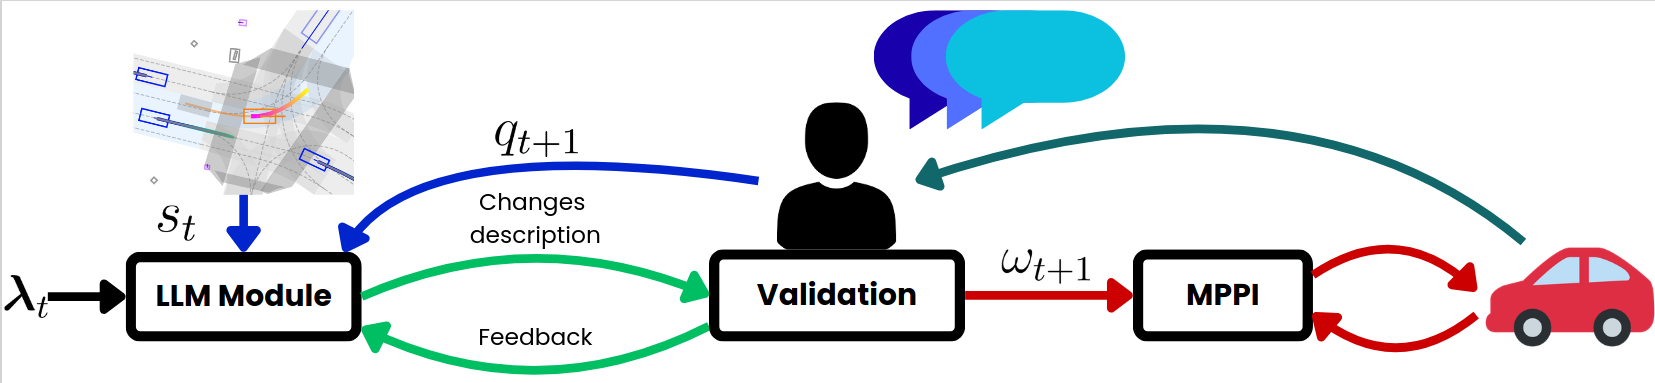
The driving behavior of autonomous vehicles is typically governed by the cost function of their motion planner, which encodes objectives such as speed tracking, smoothness, lane keeping, and collision avoidance. However, tuning the parameters that shape this cost function is a challenging task that requires technical expertise, limiting the vehicle's ability to adapt to evolving traffic scenarios or end-user preferences. This work presents a language-driven framework for adaptive cost design in autonomous driving. A Large Language Model (LLM) interprets structured scenario descriptions and natural language user queries to generate the parameters applied to a risk-aware Model Predictive Path Integral (MPPI) controller. The system incorporates a human-in-the-loop validation stage in which the proposed behavioral changes are described in non-technical language and confirmed prior to deployment. Users may additionally provide feedback either before or after deployment, enabling iterative refinement of the vehicle's motion behavior. The framework is evaluated across multiple queries in realistic driving scenarios to assess its effectiveness. Simulation results demonstrate that our method successfully induces behavioral changes that align with the intended requirements in an intuitive manner, thereby bridging the gap between intelligent vehicle control systems and end users.
paper image

Automatic Personalized Limbed Robot Design from Media Inputs
Gang Chen, Moji Shi, Yu Xing, Marija Popovic, Javier Alonso-Mora, Lei Zhang, Jiangmiao Pang. In npj Robotics, 2026.

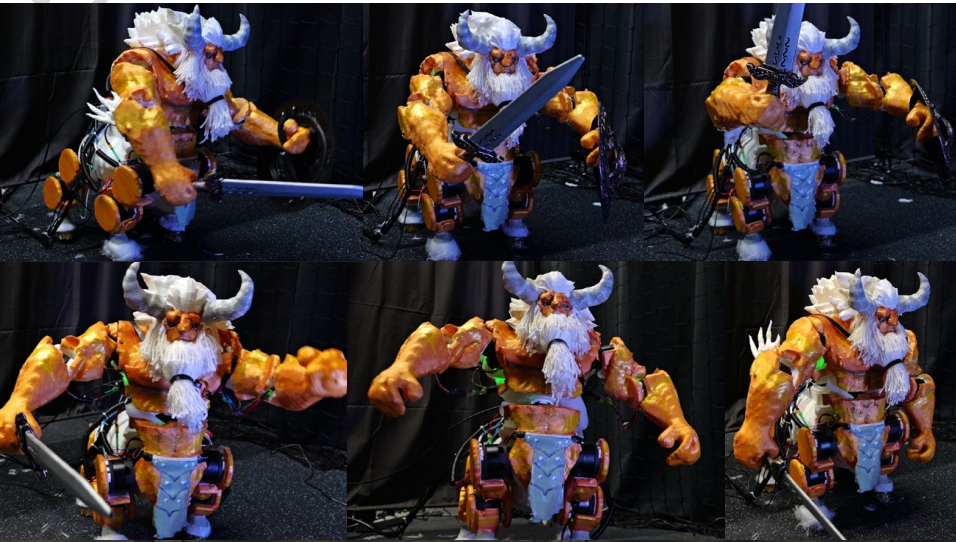
Designing limbed robots is a complex, multidisciplinary task that typically requires substantial effort from experienced engineers. In this paper, we present a novel automatic robot design framework based on Decomposition-Optimization-Assembling (DOA) to address this challenge. Our framework enables non-experts to create personalized limbed robot designs from media inputs, such as text and images, within minutes to a few hours. Our system leverages recent advances in generative AI and 3D printing to produce designs that match the descriptions provided in the input media. The output consists of selected motors and 3D-printable mechanical components that can be assembled into a limbed robot. To handle the large design space and intricate details in fabrication and assembly, we formulate and solve a series of optimization problems involving actuators, geometry, and structural density. We validate the proposed system by designing and fabricating a centaur robot based on an image input. Furthermore, we demonstrate the system's versatility and effectiveness through the generation of a wide variety of limbed robot designs.
paper image

Safety on the Fly: Constructing Robust Safety Filters Via Policy Control Barrier Functions At Runtime
Luzia Knoedler, Oswin So, Ji Yin, Mitchell Black, Zachary Serlin, Panagiotis Tsiotras, Javier Alonso-Mora, Chuchu Fan. In IEEE Robotics and Automation Letters (RA-L), 2025.
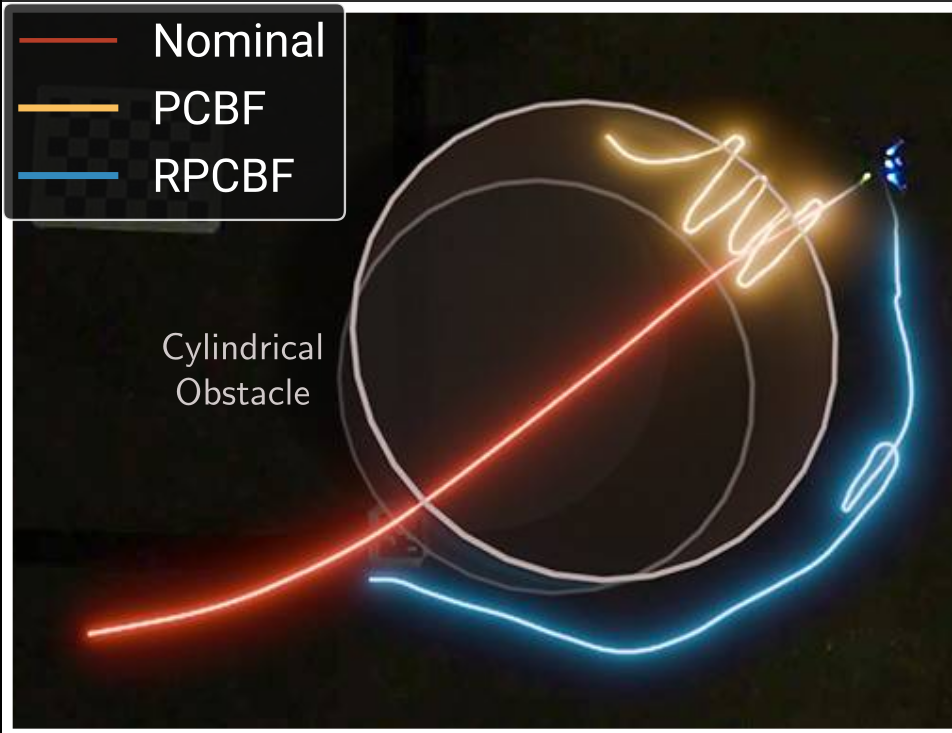
Control Barrier Functions (CBFs) have proven to be an effective tool for performing safe control synthesis for nonlinear systems. However, guaranteeing safety in the presence of disturbances and input constraints for high relative degree systems is a difficult problem. In this work, we propose the Robust Policy CBF (RPCBF), a practical approach for constructing robust CBF approximations online via the estimation of a value function. We establish conditions under which the approximation qualifies as a valid CBF and demonstrate the effectiveness of the RPCBF-safety filter in simulation on a variety of high relative degree input-constrained systems. Finally, we demonstrate the benefits of our method in compensating for model errors on a hardware quadcopter platform by treating the model errors as disturbances.
paper image