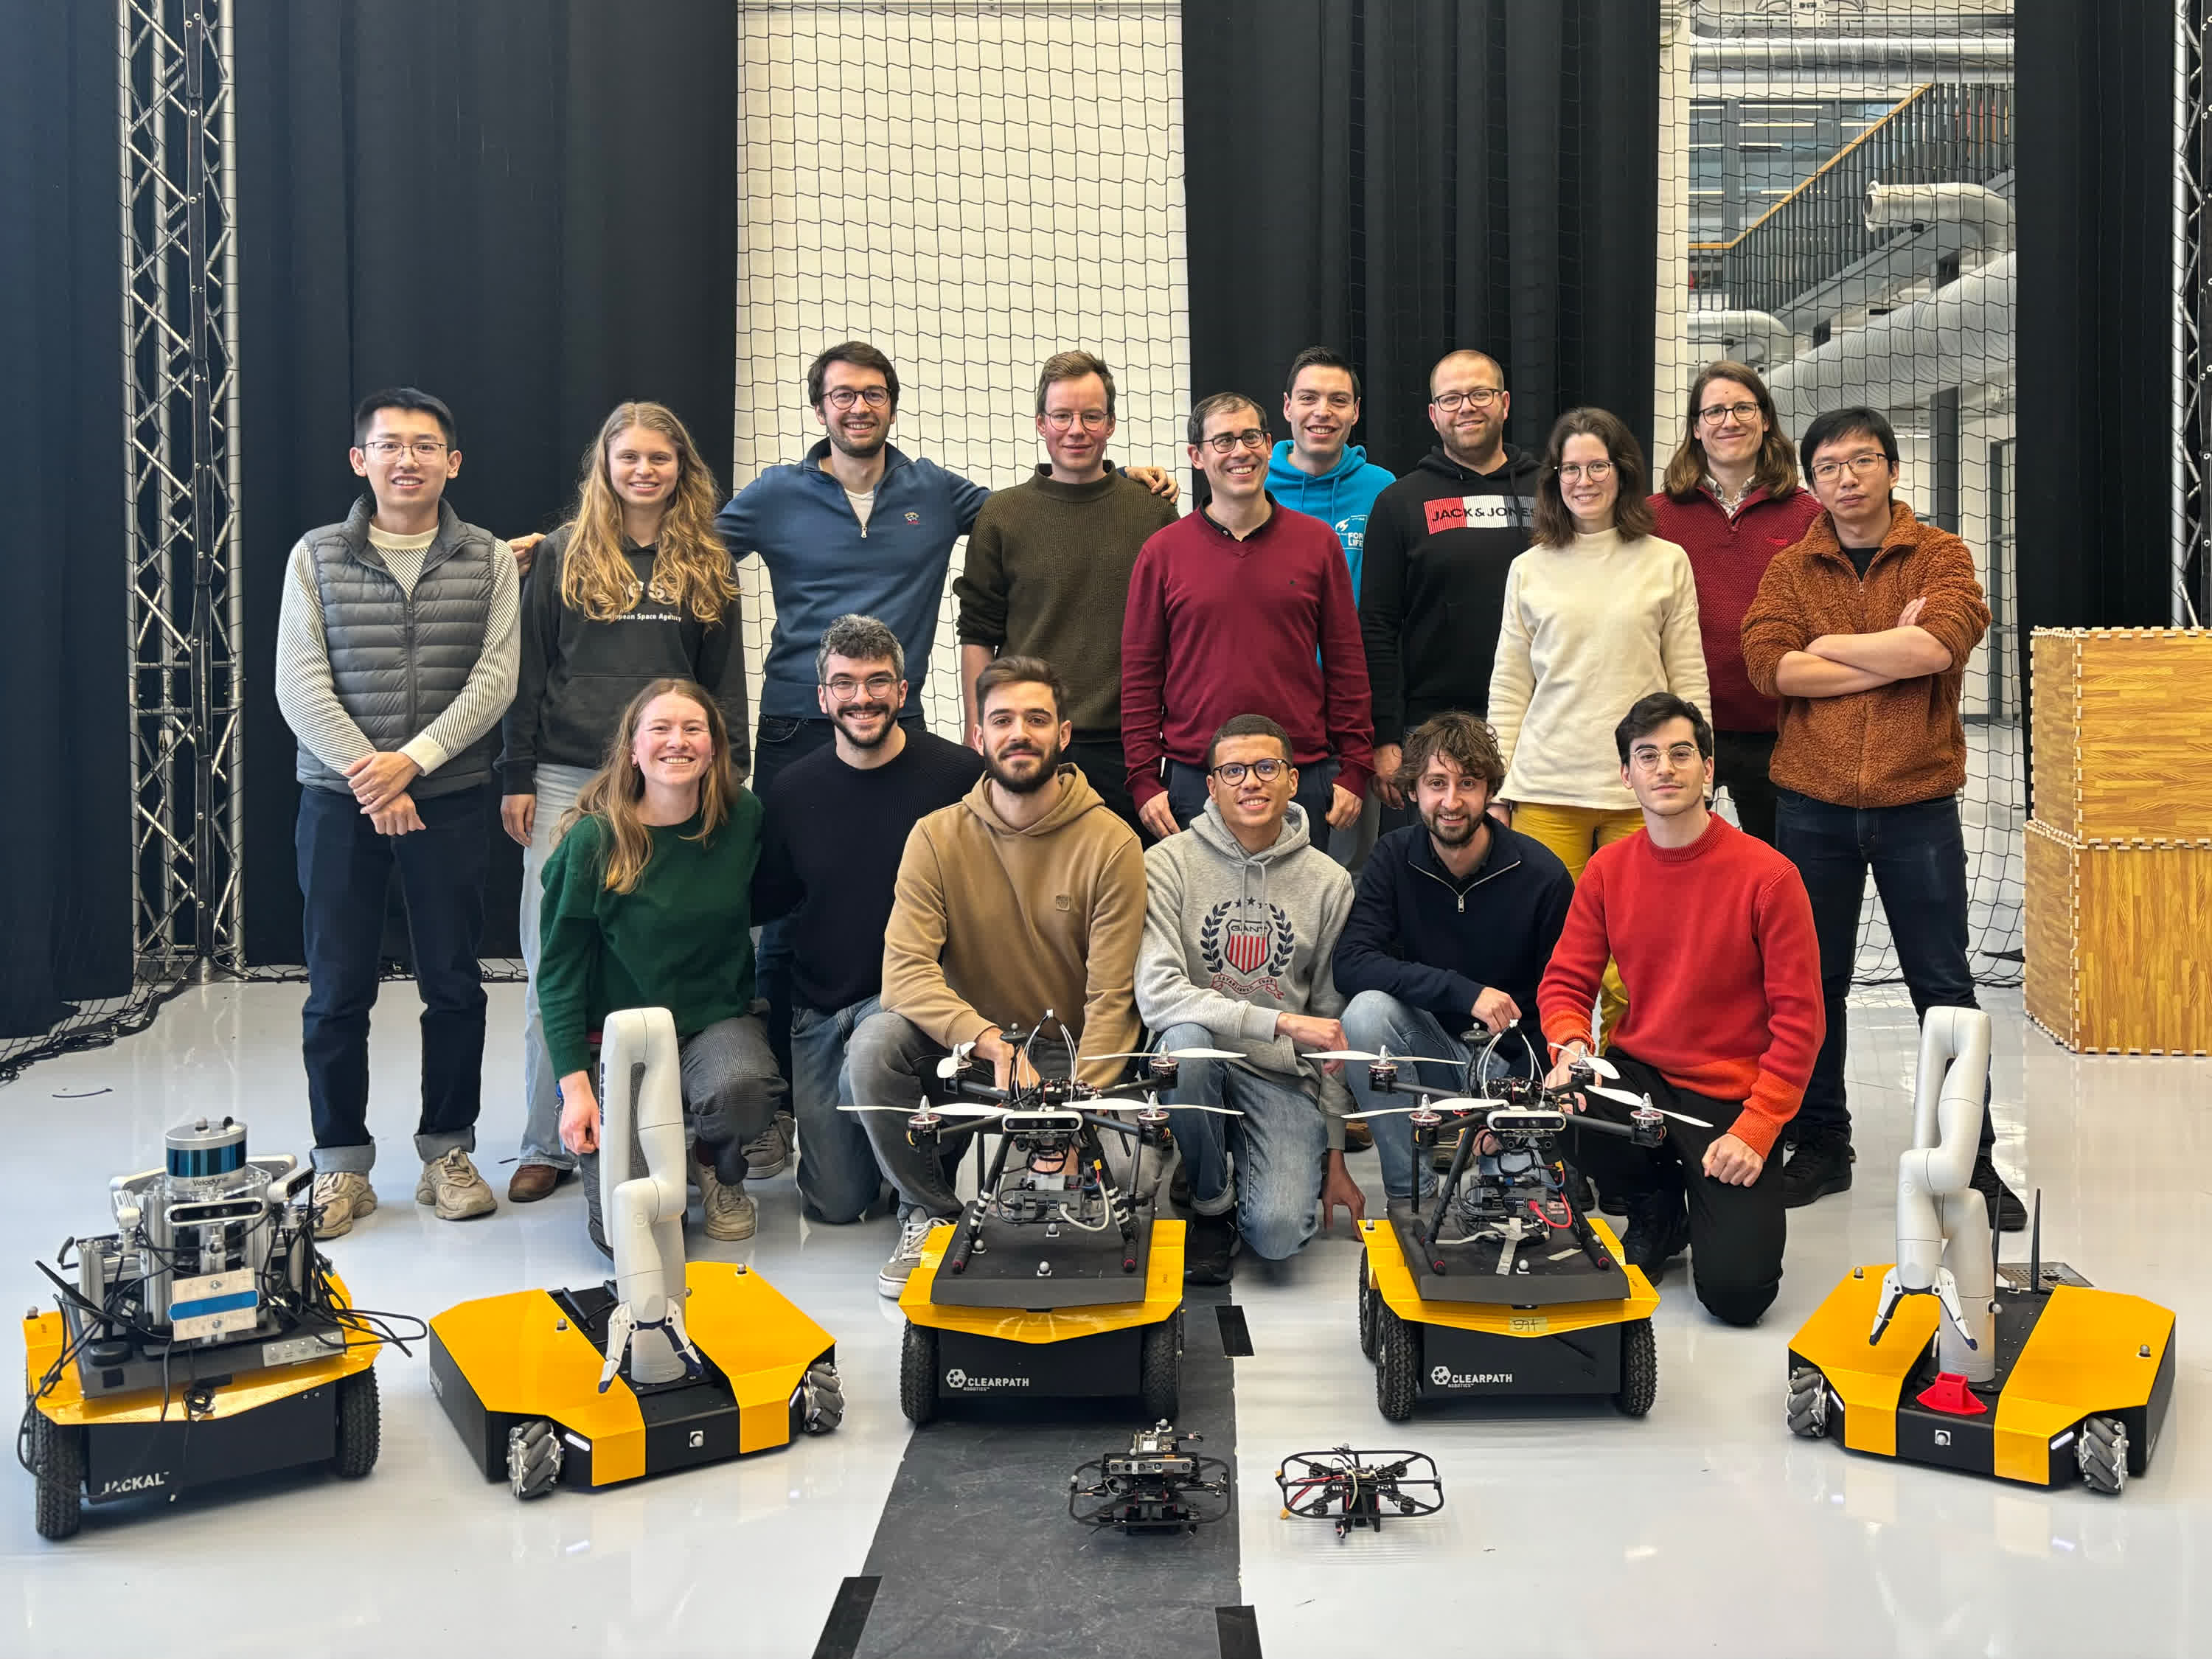
We are the Autonomous Multi-Robots Lab!
Our main research interests are in navigation, motion planning, learning, and control of autonomous mobile robots, and teams thereof, that interact with other robots and humans in dynamic and uncertain environments.
We contribute novel methods and solutions in the areas of motion planning, dynamic vehicle routing, multi-robot coordination, multi-robot learning, task assignment, active perception, formation control, collision avoidance and human-swarm interaction. Building towards the smart industries and cities of the future, we apply these techniques in various fields, including autonomous cars, automated factories, aerial vehicles, autonomous vessels, mobile manipulation and intelligent transportation systems with ride-sharing.
You can also read more about some of our research in this TU Delft story.
Research
Our group's research is applied mainly to the following fields:
- Autonomous Vehicles
- Entertainment and Education Robots
- Flying Robots
- Mobile Manipulation
- Social Robots
- On-Demand Transportation
Watch demos and paper videos on our YouTube playlist, or find our code on GitHub.
Latest publications
See all publications-
 Flow Policies as Actions of Skill-Level World Models: Learned and Symbolic Abstractions for Long-Horizon Planning
-
 Learning Task and Motion Plans from Real Demonstrations with Hybrid Flow Matching
-
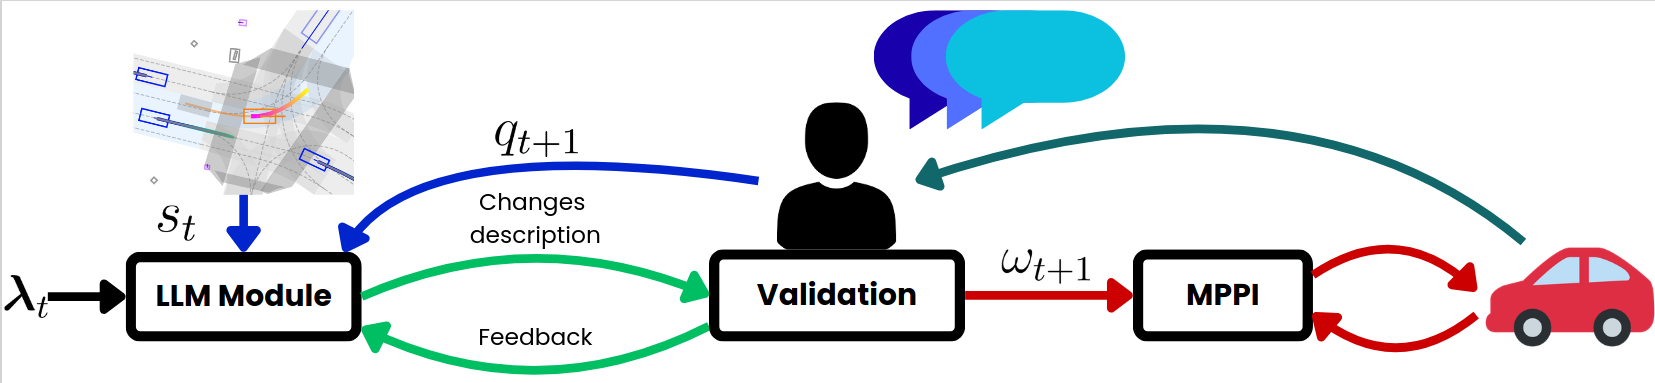 Language-Driven Cost Optimization for Autonomous Driving
-
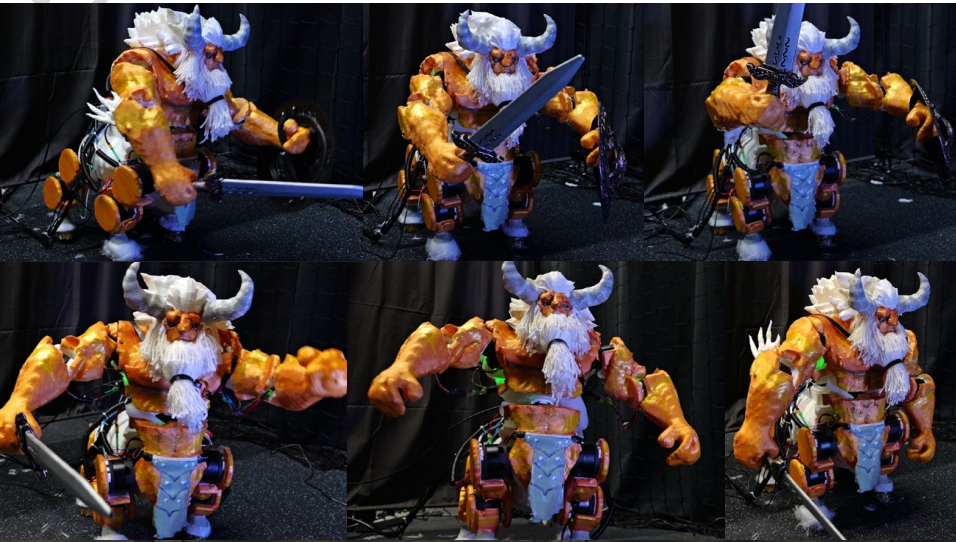 Automatic Personalized Limbed Robot Design from Media Inputs
Latest news
-
August 2026
Our research featured in IEEE Spectrum!
IEEE Spectrum featured our work on language-driven personalization of autonomous driving, where passengers can adapt the driving behavior of a safety-aware motion planner through natural-language requests. Read the article here.
-
October 2025
New Science Robotics paper published!
We’re thrilled to share that our paper, “Agile and Cooperative Aerial Manipulation of a Cable-Suspended Load,” has been published in Science Robotics. This work was led by Dr. Sihao Sun as part of his Veni project.
-
July 2025
Submissions open for IROS workshop!
We’re excited to announce that submissions are now open for the IROS 2025 workshop “Perception and Planning for Mobile Manipulation in Changing Environments,” which we’re co-organizing. Workshop website
-
May 2025
Our NWO OTP project FlexMobility awarded!
Excited to announce that we have been granted an NWO OTP project to work at the intersection of fixed and flexible on-demand mobility for public transit. Read more here
Show all news (19)
-
May 2025
Lasse Peters has been named RSS Pioneer 🏆
Lasse Peters has been named RSS Pioneer. Find the full list of awardees and their contributions on the RSS Pioneers website.
-
March 2025
Congratulations to Dr. Elia Trevisan for successfully defending his PhD thesis!
Elia Trevisan successfully defended his PhD thesis titled "Model Predictive Path Integral Control for Interaction-Rich Local Motion Planning in Dynamic Environments".
-
March 2025
Our ONR Global project SECURE awarded!
We are grateful to ONR Global for the support of our project SECURE! We will work on secure multi-robot interaction with one PhD candidate.
-
December 2024
Congratulations to Dr. Max Spahn for successfully defending his PhD thesis!
Max Spahn successfully defended his PhD thesis titled "Trajectory Generation for Mobile Manipulators with Differential Geometry: Behavior Encoding beyond Model Predictive Control".
-
December 2024
Congratulations to Dr. Oscar de Groot for successfully defending his PhD thesis!
Oscar de Groot successfully defended his PhD thesis titled "Probabilistic Motion Planning in Dynamic Environments: Parallelizable Scenario-Based Trajectory Optimization with Global Guidance".
-
August 2024
Our work received the 2024 IEEE T-ASE Best Paper Award.
Our paper "Group-Based Distributed Auction Algorithms for Multi-Robot Task Assignment" has received the 2024 IEEE Transactions on Automation Science and Engineering Best Paper Award.
-
May 2024
A new paper published at IEEE Transactions on Intelligent Vehicles (T-IV).
We have a new paper titled "RACP: Risk-Aware Contingency Planning with Multi-Modal Predictions" published at T-IV! See publications for details.
-
May 2024
Our work will be presented at WAFR 2024.
Our paper "Auto-Encoding Bayesian Inverse Games" has been accepted to the 16th International Workshop on the Algorithmic Foundations of Robotics (WAFR) in Chicago.
-
February 2024
CMU guest lecture on "Game-Theoretic Models for Mult-Agent Interaction"
Lasse Peters gave a guest lecture on "Game-Theoretic Models for Mult-Agent Interaction" as part of the CMU special topics class on "Models & Algorithms for Interactive Robotics". A recording of the lecture is available here.
-
November 2023
IEEE International Symposium on Multi-Robot and Multi-Agent Systems (MRS)
We will be presenting three papers in IEEE International Symposium on Multi-Robot and Multi-Agent Systems (MRS) in Boston! See publications for details.
-
September 2023
Workshop on Human Multi-Robot Interaction at IROS 2023
We are co-organizing the Workshop on Human Multi-Robot Interaction at IROS 2023. Check out the workshop's website for details.
-
July 2023
We Have A New Paper at RA-L
We have a new paper: Optimizing Task Waiting Times in Dynamic Vehicle Routing published at RA-L! See publications for details.
-
May 2023
Multiple papers in ICRA and IV
We will be presenting multiple papers in ICRA and IV! See publications for details.
-
March 2022
ERC Starting grant for INTERACT
I am honored to have received an ERC Starting grant for my project Intuitive Interaction for Robots among Humans (INTERACT)! Read more.
-
June 2019
ICRA Best Paper Award in Multi-Robot Systems
We won the IEEE ICRA Best Paper Award in Multi-Robot Systems!! Congrats Hai, Jelle and Laura!