Active Disturbance Rejection Control (ADRC) for Trajectory Tracking of a Seagoing USV: Design, Simulation, and Field Experiments
Abstract
Unmanned Surface Vessels (USVs) face significant control challenges due to uncertain environmental disturbances like waves and currents. This paper proposes a trajectory tracking controller based on Active Disturbance Rejection Control (ADRC) implemented on the DUS V2500. A custom simulation incorporating realistic waves and current disturbances is developed to validate the controller's performance, supported by further validation through field tests in the harbour of Scheveningen, the Netherlands, and at sea. Simulation results demonstrate that ADRC significantly reduces cross-track error across all tested conditions compared to a baseline PID controller but increases control effort and energy consumption. Field trials confirm these findings while revealing a further increase in energy consumption during sea trials compared to the baseline.
Related Publications
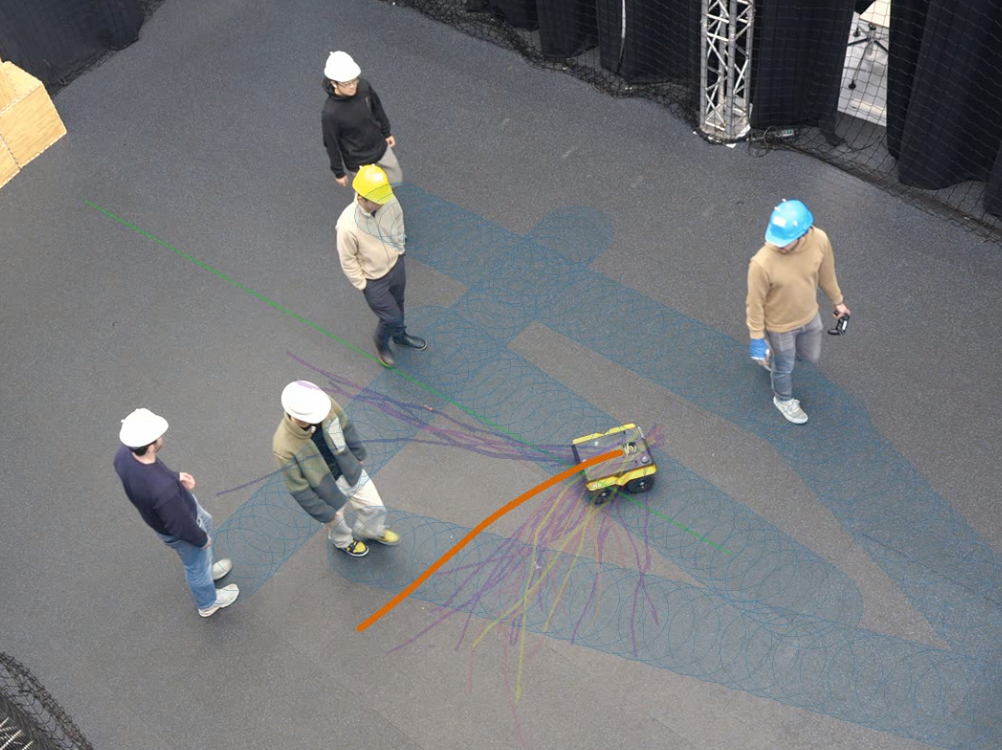
Dynamic Risk-Aware MPPI for Mobile Robots in Crowds via Efficient Monte Carlo Approximations
In IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), 2025.
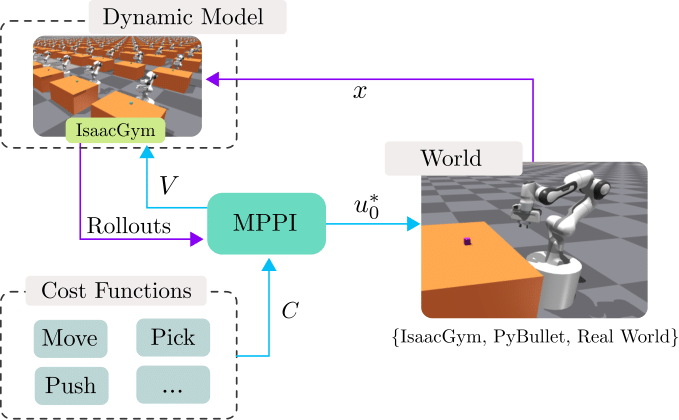
Sampling-based Model Predictive Control Leveraging Parallelizable Physics Simulations
In IEEE Robotics and Automation Letters (RA-L), 2025.
Multi-Modal MPPI and Active Inference for Reactive Task and Motion Planning
In IEEE Robotics and Automation Letters (RA-L), 2024.
Biased-MPPI: Informing Sampling-Based Model Predictive Control by Fusing Ancillary Controllers
In IEEE Robotics and Automation Letters (RA-L), 2024.
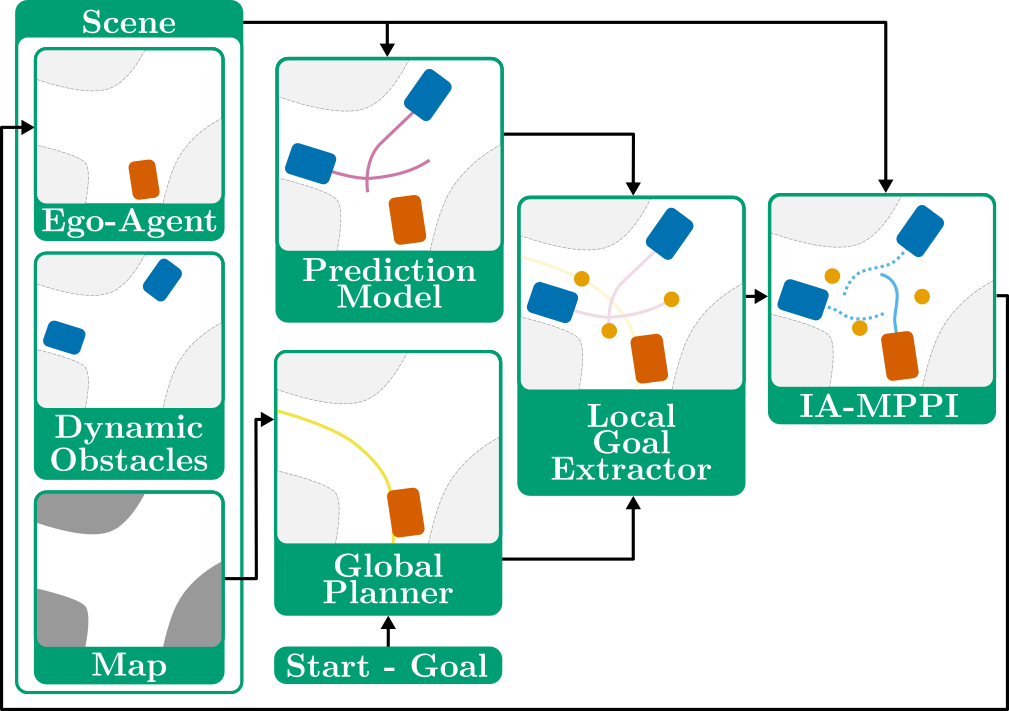
Interaction-Aware Sampling-Based MPC with Learned Local Goal Predictions
In Proc. IEEE International Symposium on Multi-Robot and Multi-Agent Systems, 2023.
Sampling-Based MPC Using a GPU-parallelizable Physics Simulator as Dynamic Model: an Open Source Implementation with IsaacGym
In Embracing Contacts Workshop at IEEE Int. Conf. on Robotics and Automation (ICRA), 2023.
Multi-Agent Path Integral Control for Interaction-Aware Motion Planning in Urban Canals
In IEEE Int. Conf. on Robotics and Automation (ICRA), 2023.
Regulations Aware Motion Planning for Autonomous Surface Vessels in Urban Canals
In Proc. IEEE Int. Conf. on Robotics and Automation (ICRA), 2022.