Interaction-Aware Sampling-Based MPC with Learned Local Goal Prediction
Abstract
Motion planning for autonomous robots in tight, interaction-rich, and mixed human-robot environments is challenging. State-of-the-art methods typically separate prediction and planning, predicting other agents’ trajectories first and then planning the ego agent’s motion in the remaining free space. However, agents’ lack of awareness of their influence on others can lead to the freezing robot problem. We build upon Interaction-Aware Model Predictive Path Integral (IAMPPI) control and combine it with learning-based trajectory predictions, thereby relaxing its reliance on communicated short-term goals for other agents. We apply this framework to Autonomous Surface Vessels (ASVs) navigating urban canals. By generating an artificial dataset in real sections of Amsterdam’s canals, adapting and training a prediction model for our domain, and proposing heuristics to extract local goals, we enable effective cooperation in planning. Our approach improves autonomous robot navigation in complex, crowded environments, with potential implications for multi-agent systems and human-robot interaction.
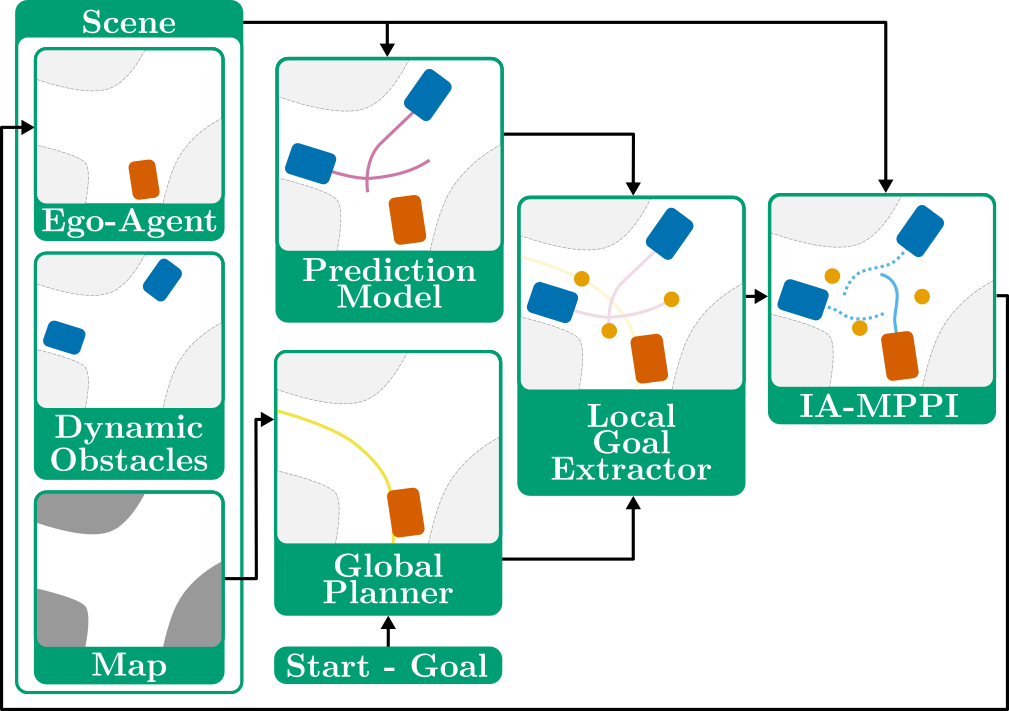
Framework
Firstly, the prediction model utilizes information from all elements in the scene to forecast trajectories for obstacle agents. Meanwhile, the global planner, equipped with the map, start, and goal positions, generates a path for the ego agent. Subsequently, the local goal extractor leverages this information to determine appropriate local goals for the motion planner. With inputs derived from the scene and the local goals, the Interaction-Aware Model Predictive Path Integral (IA-MPPI) algorithm simultaneously plans and predicts input sequences for all agents in the scene. The first input of the sequence is then assigned to the ego agent, and the algorithm iterates.
Related Publications
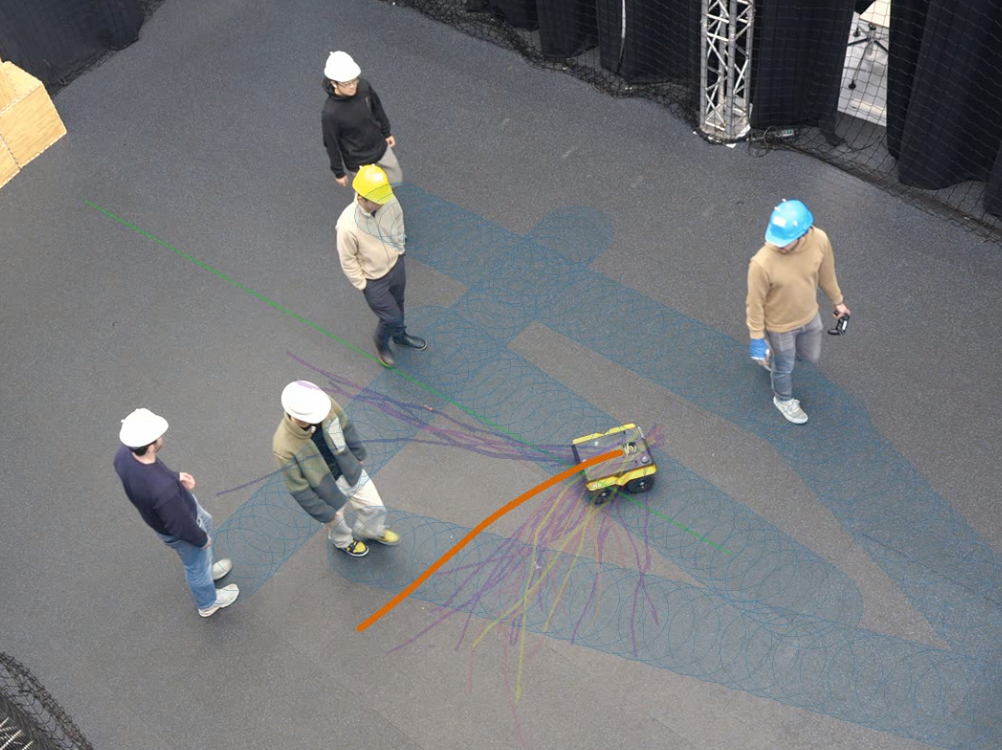
Dynamic Risk-Aware MPPI for Mobile Robots in Crowds via Efficient Monte Carlo Approximations
In IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), 2025.
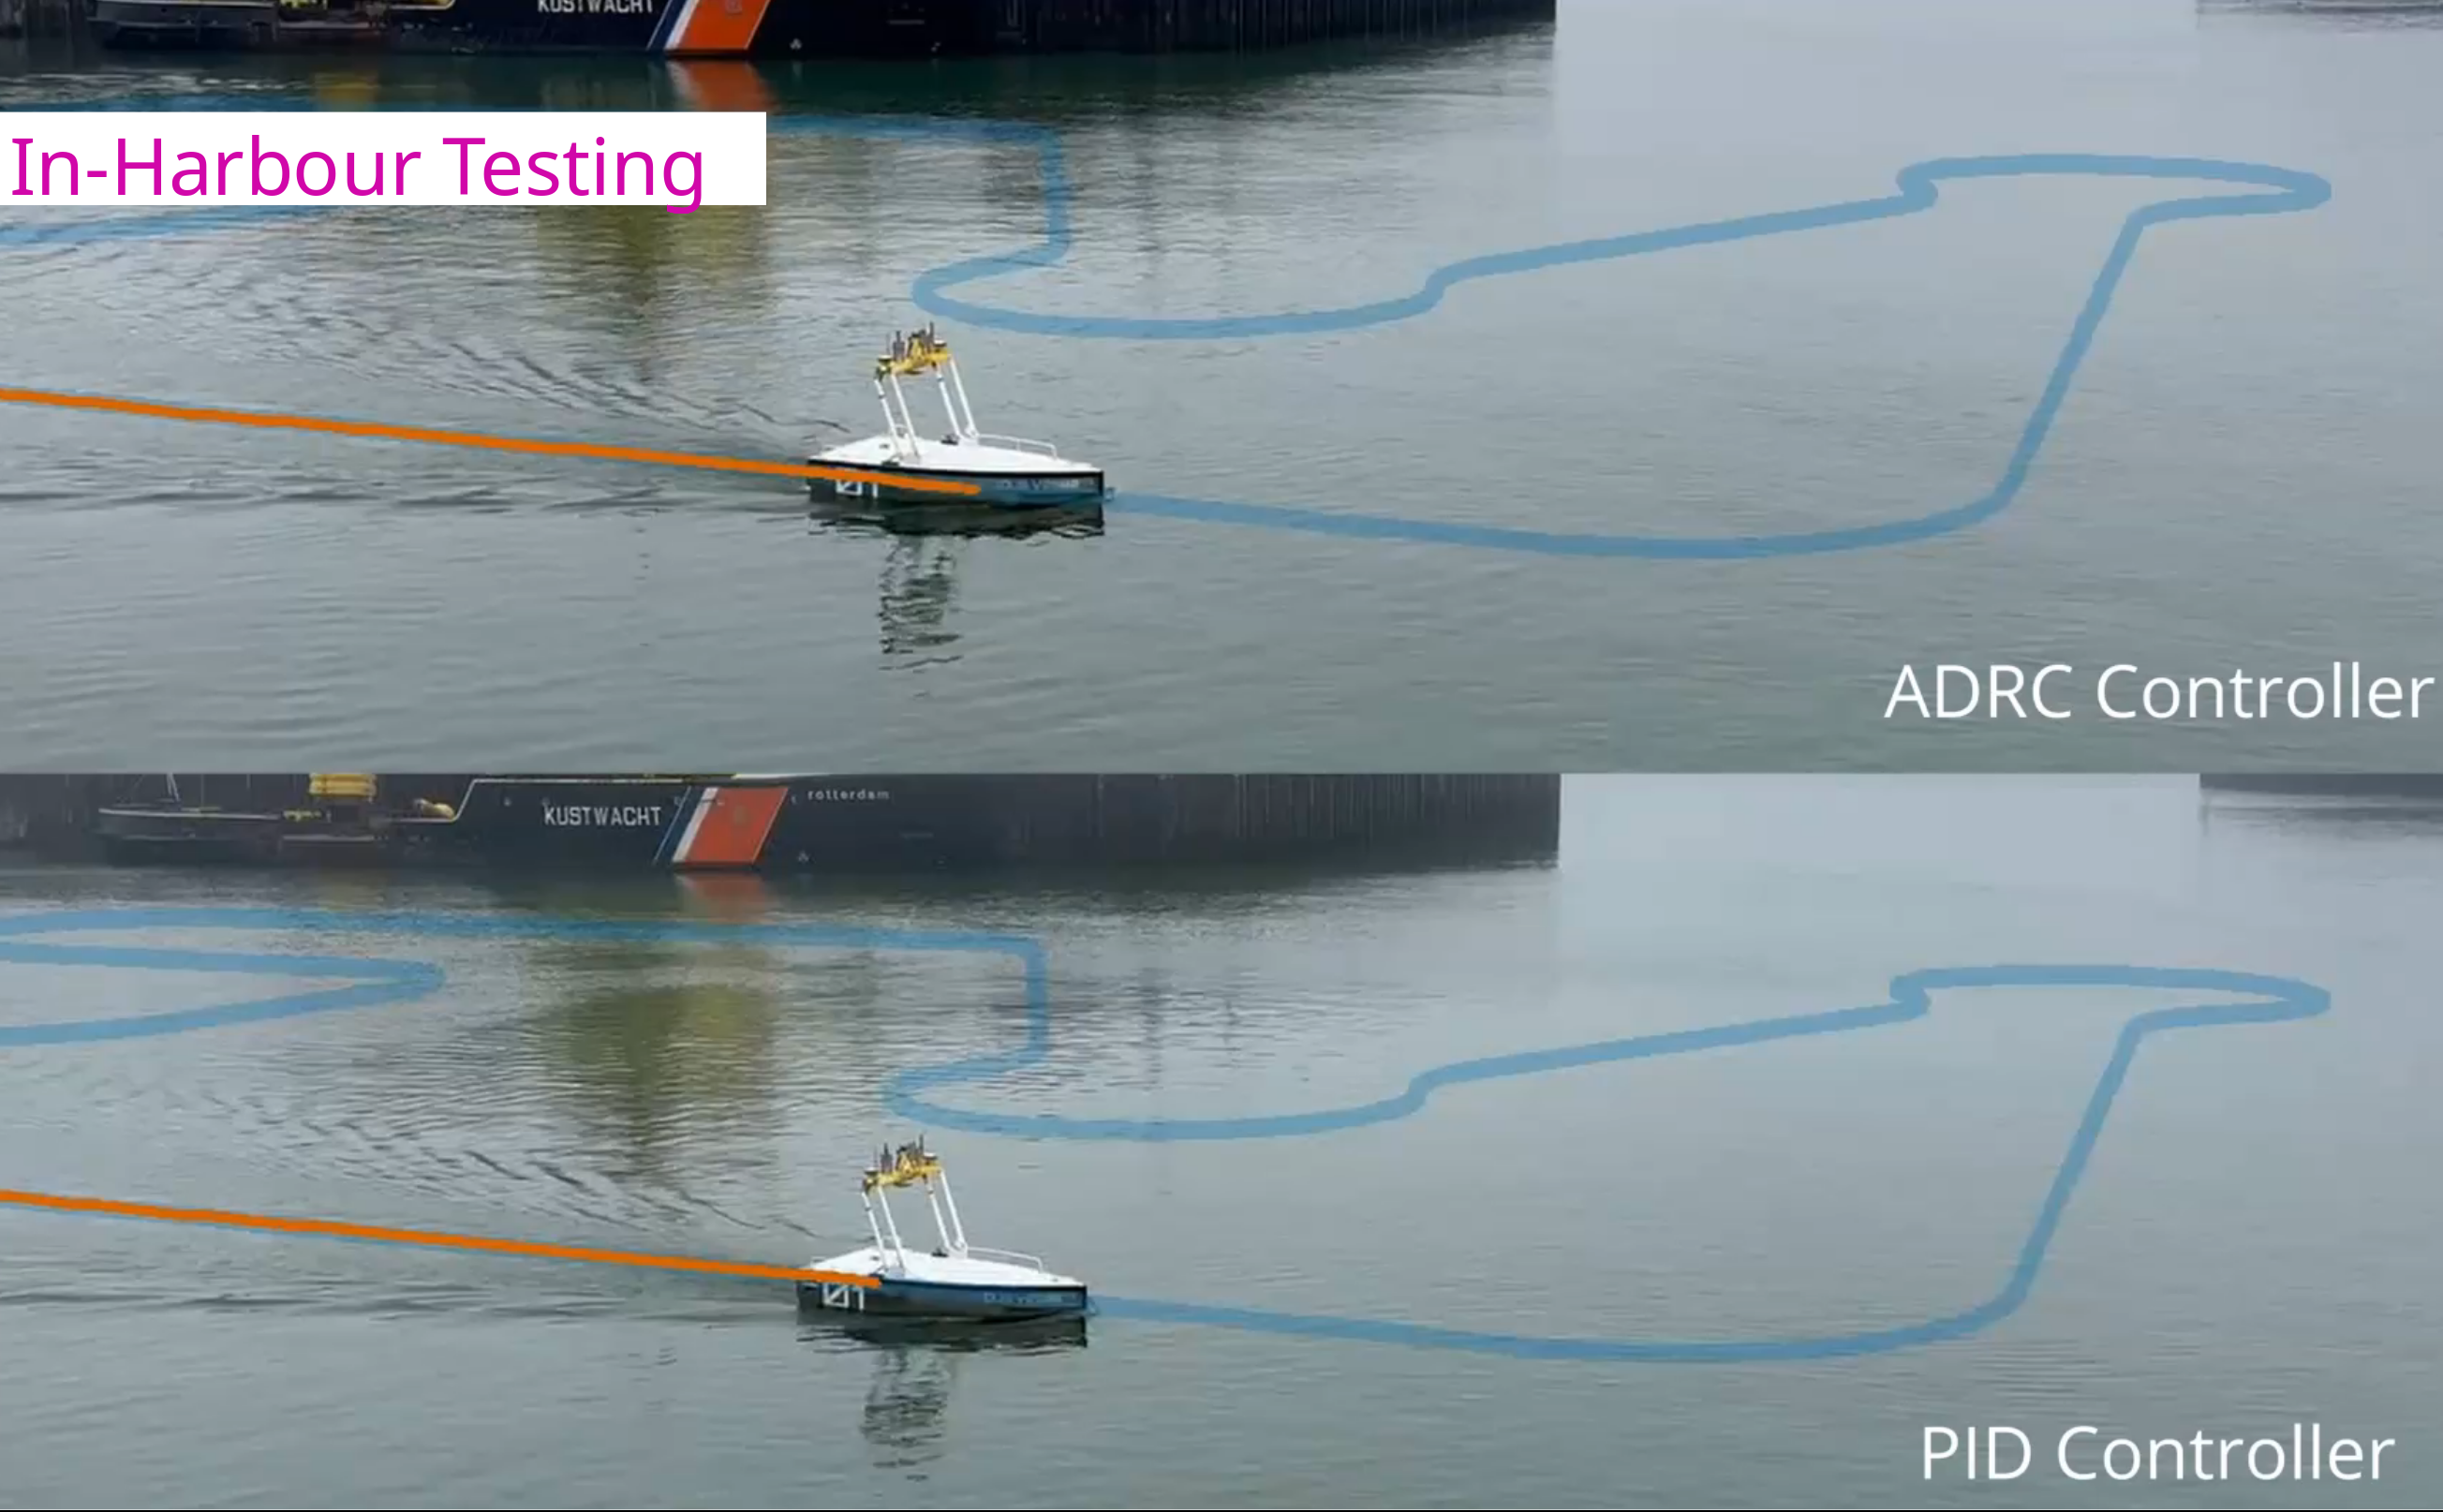
Active Disturbance Rejection Control (ADRC) for Trajectory Tracking of a Seagoing USV: Design, Simulation, and Field Experiments
In IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), 2025.
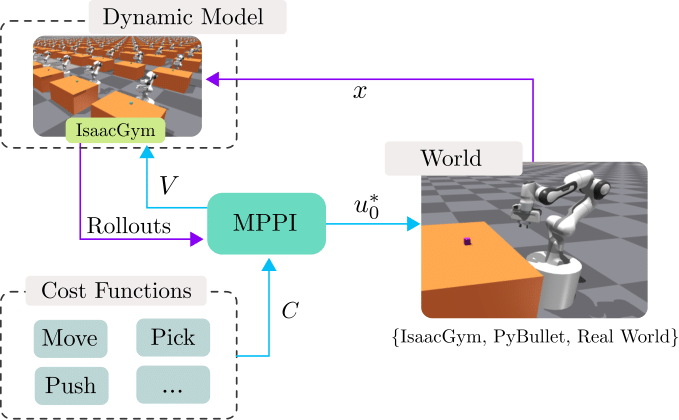
Sampling-based Model Predictive Control Leveraging Parallelizable Physics Simulations
In IEEE Robotics and Automation Letters (RA-L), 2025.
Multi-Modal MPPI and Active Inference for Reactive Task and Motion Planning
In IEEE Robotics and Automation Letters (RA-L), 2024.
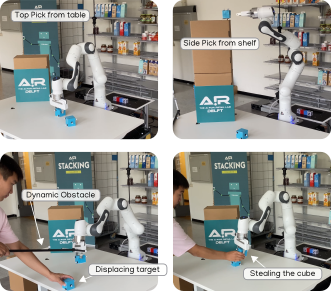
Biased-MPPI: Informing Sampling-Based Model Predictive Control by Fusing Ancillary Controllers
In IEEE Robotics and Automation Letters (RA-L), 2024.
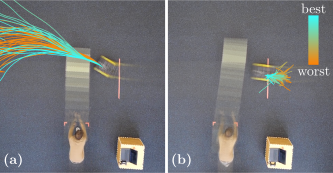
Interaction-Aware Sampling-Based MPC with Learned Local Goal Predictions
In Proc. IEEE International Symposium on Multi-Robot and Multi-Agent Systems, 2023.
Sampling-Based MPC Using a GPU-parallelizable Physics Simulator as Dynamic Model: an Open Source Implementation with IsaacGym
In Embracing Contacts Workshop at IEEE Int. Conf. on Robotics and Automation (ICRA), 2023.
Multi-Agent Path Integral Control for Interaction-Aware Motion Planning in Urban Canals
In IEEE Int. Conf. on Robotics and Automation (ICRA), 2023.
Regulations Aware Motion Planning for Autonomous Surface Vessels in Urban Canals
In Proc. IEEE Int. Conf. on Robotics and Automation (ICRA), 2022.