Sampling-based Model Predictive Control Leveraging Parallelizable Physics Simulations
*Equal contribution 1TU Delft
Omnidirectional Push w Disturbances
Manipulator Push w Disturbances
Manipulator Push Left
Manipulator Push Right
Abstract
We present a method for sampling-based model predictive control that makes use of a generic physics simulator as the dynamical model. In particular, we propose a Model Predictive Path Integral controller (MPPI), that uses the GPU-parallelizable IsaacGym simulator to compute the forward dynamics of a problem. By doing so, we eliminate the need for manual encoding of robot dynamics and interactions among objects and allow one to effortlessly solve complex navigation and contact-rich tasks. Since no explicit dynamic modeling is required, the method is easily extendable to different objects and robots. We demonstrate the effectiveness of this method in several simulated and real-world settings, among which mobile navigation with collision avoidance, non-prehensile manipulation, and whole-body control for high-dimensional configuration spaces. This method is a powerful and accessible tool to solve a large variety of contact-rich motion planning tasks.
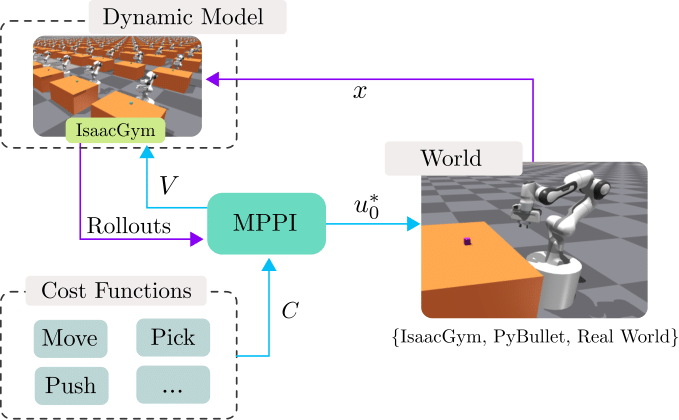
Figure 1: Scheme of the proposed method using IsaacGym as the dynamic model for MPPI. At each time step, IsaacGym is reset to the current world's state $x$, and random input sequences ${V}$ are applied for the horizon $T$, to every environment. The resulting rolled-out trajectories are used by MPPI to approximate the optimal control $u_0^*$ given a cost function $C$.
Omidirectional Motion Planning
Manipulator Motion Planning
Omnidirectional Box Push
Collision avoidance with the obstacles
Omnidirectional Box Push
Collision avoidance with the obstacles
Omnidirectional Ball Roll
Change object: roll against obstacles
Omnidirectional Ball Roll
Change object: roll against obstacles
Differential Drive Box Push
Change robot: just change the URDF!
12-DOF Pick and Delivery
Control velocity of all joints, including fingers.
Manipulator Push
Keep the same orientation
Manipulator Push
Rotatate $90^\circ$
Manipulator Push
Keep the same orientation
Manipulator Push
Rotatate $30^\circ$
Related Publications
Dynamic Risk-Aware MPPI for Mobile Robots in Crowds via Efficient Monte Carlo Approximations
In IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), 2025.
Active Disturbance Rejection Control (ADRC) for Trajectory Tracking of a Seagoing USV: Design, Simulation, and Field Experiments
In IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), 2025.
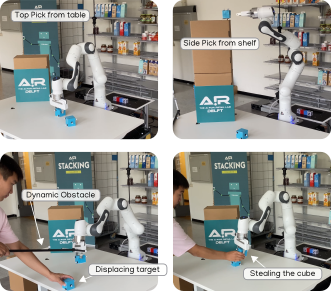
Multi-Modal MPPI and Active Inference for Reactive Task and Motion Planning
In IEEE Robotics and Automation Letters (RA-L), 2024.
Biased-MPPI: Informing Sampling-Based Model Predictive Control by Fusing Ancillary Controllers
In IEEE Robotics and Automation Letters (RA-L), 2024.
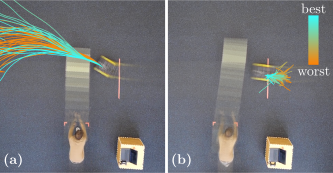
Interaction-Aware Sampling-Based MPC with Learned Local Goal Predictions
In Proc. IEEE International Symposium on Multi-Robot and Multi-Agent Systems, 2023.
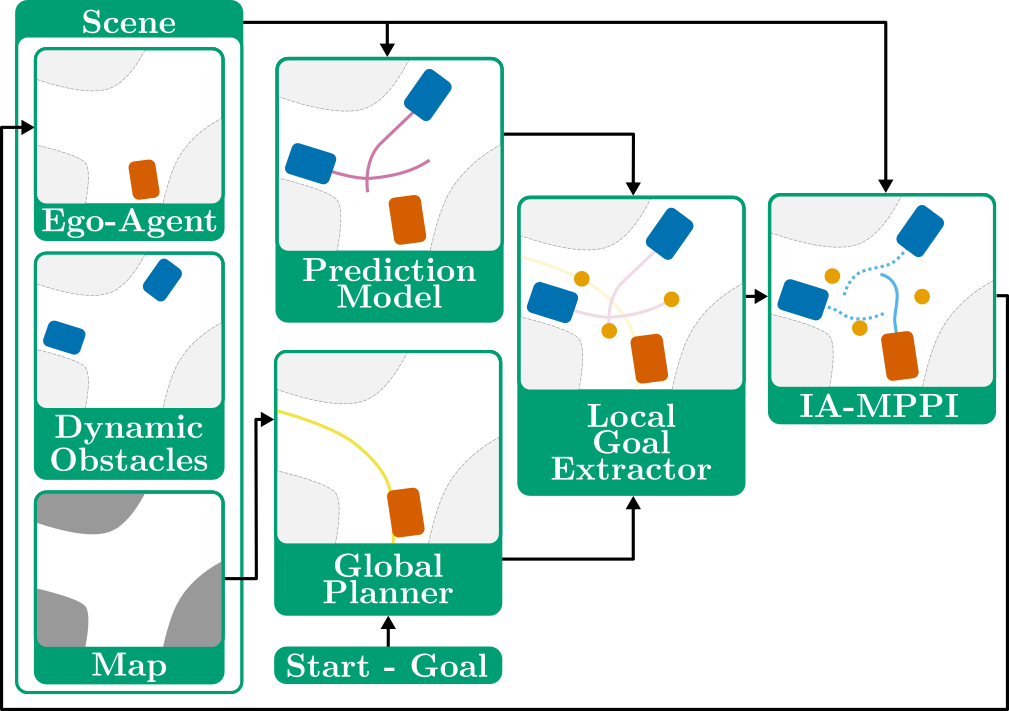
Sampling-Based MPC Using a GPU-parallelizable Physics Simulator as Dynamic Model: an Open Source Implementation with IsaacGym
In Embracing Contacts Workshop at IEEE Int. Conf. on Robotics and Automation (ICRA), 2023.
Multi-Agent Path Integral Control for Interaction-Aware Motion Planning in Urban Canals
In IEEE Int. Conf. on Robotics and Automation (ICRA), 2023.
Regulations Aware Motion Planning for Autonomous Surface Vessels in Urban Canals
In Proc. IEEE Int. Conf. on Robotics and Automation (ICRA), 2022.