PostDoc-Multi
About the Project
Multi-robot teams can be employed for various tasks, such as surveillance, inspection, and automated factories. In these scenarios, robots may be required to navigate in formation, for example, to maintain a communication network, to collaboratively manipulate an object, or to survey an area. In the near future, assembly systems will incorporate mobile robots to make manufacturing adaptable to changing circumstances, including the manipulation of soft objects that require many hands to control. Within multi-robot navigation, formation control and reconfiguration in presence of moving obstacles remains challenging. This project aims to build a method for collaborative manipulation of objects having variable shape. Various optimization techniques are used to provide good computational efficiency and build algorithms which enable a team of robots to navigate in formation.
The first contribution from this project is a method that can optimise the parameters for a manipulator formation to help avoid moving obstacles and progress towards the goal. This method helps guarantee that the team of mobile robots will not collide with obstacles and a global path planner is provided to build a graph of feasible robot formations. This approach is validated with both a team of aerial vehicles as well as with three mobile manipulators that carry a rigid object.
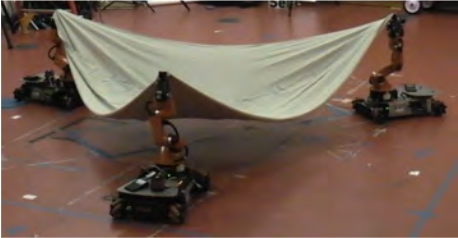
Another contribution of this project was a local planner that helps in collaborative manipulation of deformable objects.Constraints for both collision avoidance and manipulation are seamlessly integrated in velocity space and a convex optimization is solved. The planner has a constraint to maintain the shape of the object as well. This method can also be used in cases where human operators and manipulators work together to carry an object. In this case either the human trajectory must be known in advance or the human operator acts as the leader while manipulators try to minimise velocity change. The proposed planner has been tested in experiments with a set of deformable objects like rope, foam mat, bed sheet and a bath towel using two to three mobile manipulators.
Project Demonstrations
Funding & Partners
This project is funded at MIT by ONR, SMART and The Boing Company