Dynamic Risk-Aware MPPI for Mobile Robots in Crowds via Efficient Monte Carlo Approximations
*Equal contribution 1TU Delft 2Damen Naval 3Queen Mary University of London
Real-Robot Experiment with Pedestrians
A Clearpath Jackal using our approach navigates among pedestrians while minimizing its Collision Probability (CP) as well as mantaining the CP below a desired threshold. Pedestrians, tracked via motion capture, have their uncertain future motion predicted by a uni-modal Gaussian Distribution.
Abstract
Deploying mobile robots safely among humans requires the motion planner to account for the uncertainty in the other agents' predicted trajectories. This remains challenging in traditional approaches, especially with arbitrarily shaped predictions and real-time constraints. To address these challenges, we propose a Dynamic Risk-Aware Model Predictive Path Integral control (DRA-MPPI), a motion planner that incorporates uncertain future motions modelled with potentially non-Gaussian stochastic predictions. By leveraging MPPI’s gradient-free nature, we propose a method that efficiently approximates the joint Collision Probability (CP) among multiple dynamic obstacles for several hundred sampled trajectories in real-time via a Monte Carlo (MC) approach. This enables the rejection of samples exceeding a predefined CP threshold or the integration of CP as a weighted objective within the navigation cost function. Consequently, DRA-MPPI mitigates the freezing robot problem while enhancing safety. Real-world and simulated experiments with multiple dynamic obstacles demonstrate DRA-MPPI’s superior performance compared to state-of-the-art approaches, including Scenario-based Model Predictive Control (S-MPC), Frenét planner, and vanilla MPPI.
Comparisons with Non-Gaussian Predictions
Although not visualized in the video, all pedestrians are predicted to have a small chance of turning left any future time-step. This is modeled with a Gaussian Mixture Model. Below is a video comparison to a state-of-the-art Scenario-Based MPC [de Groot, 2023], more comparisons are provided in the tables and figures of the paper.
DRA-MPPI (Ours)
Scenario-Based MPC
Comparisons with Gaussian Predictions
Below are the video comparisons showing a Jackal robot navigating a corridor with an increasing number of pedestrians. Pedestrian motion is simulated with a social forces model, but are predicted by the robot by a Gaussian distribution centered on a constant velocity model. This mismatch is added to make the simulation more realistic, as the prediction will not perfectly match actual motion. Comparisons with several other approaches are presented in the tables and figures in our paper.
DRA-MPPI (Ours)
Four pedestrians
Scenario-Based MPC
Four pedestrians
Eight pedestrians
Eight pedestrians
Twelve pedestrians
Twelve pedestrians
Related Publications
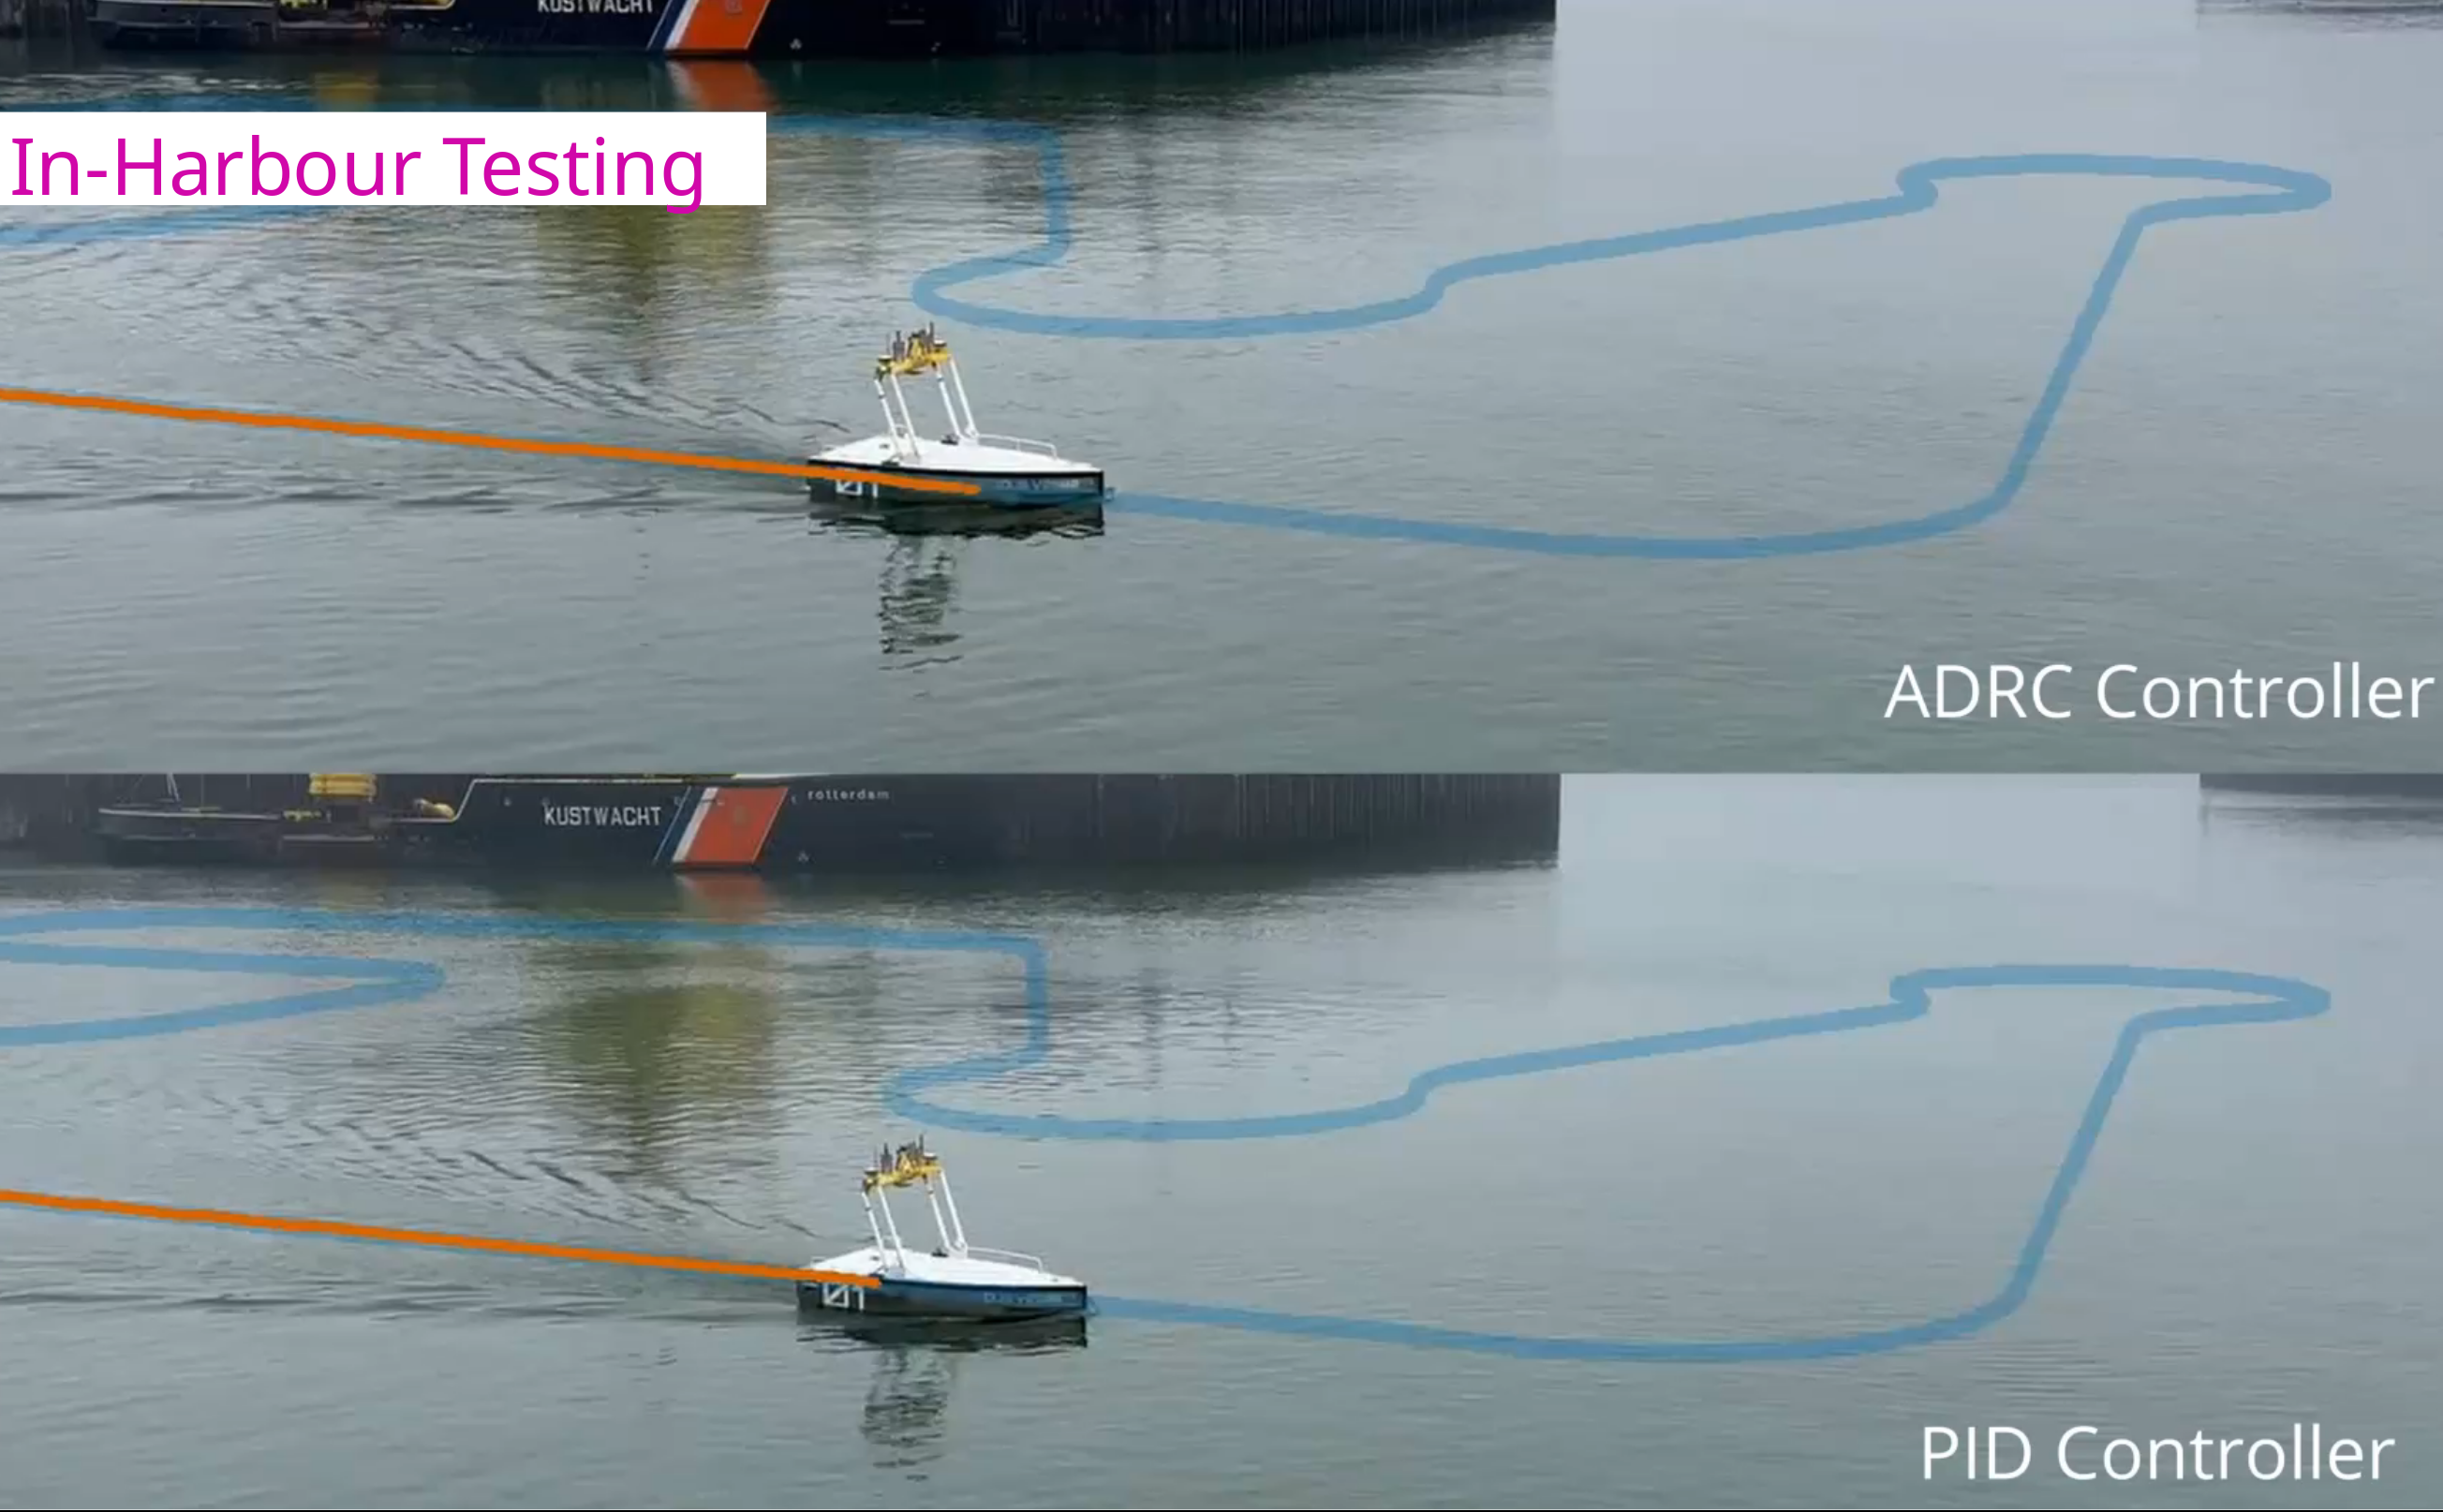
Active Disturbance Rejection Control (ADRC) for Trajectory Tracking of a Seagoing USV: Design, Simulation, and Field Experiments
In IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), 2025.
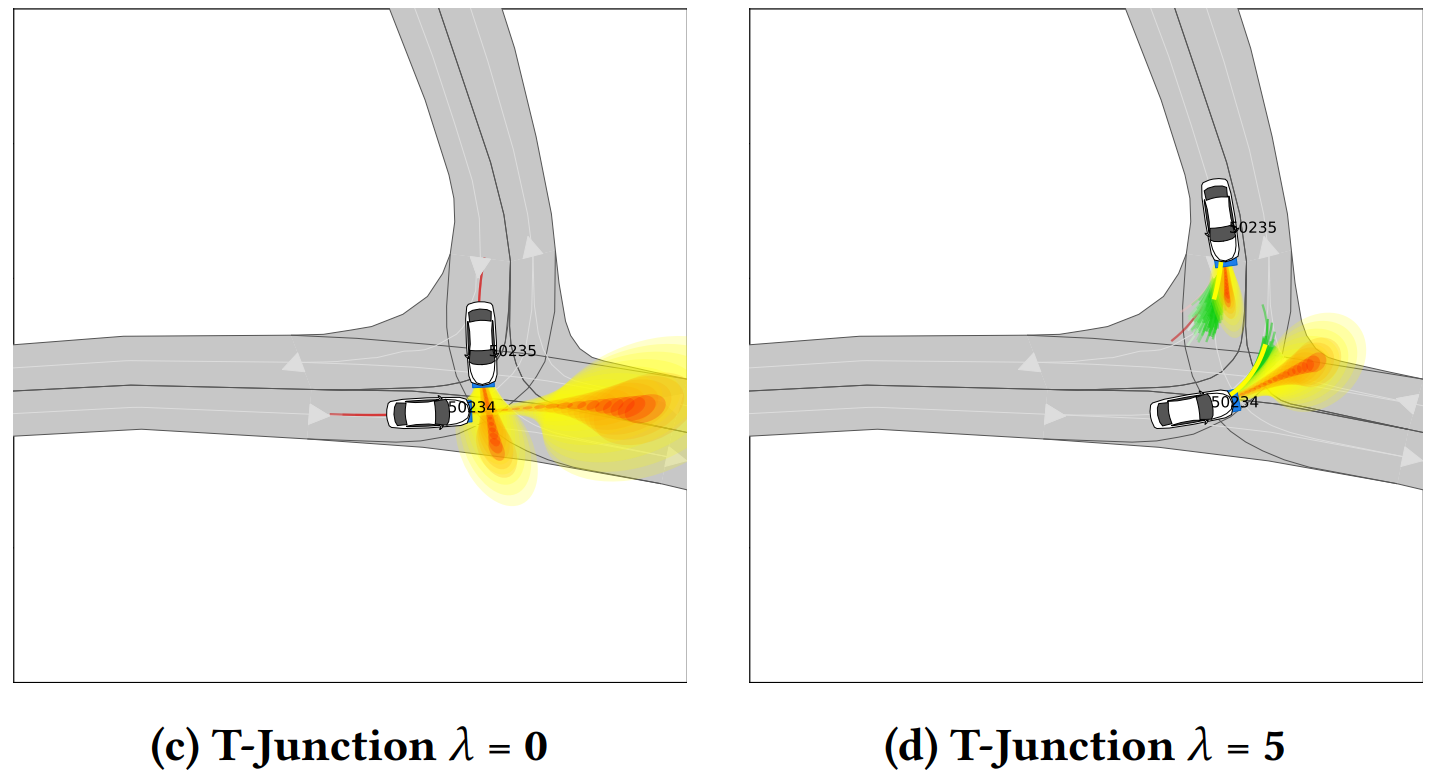
Predictability Awareness For Efficient and Robust Multi-Agent Coordination
In 24th International Conference on Autonomous Agents and Multiagent Systems (AAMAS), 2025.
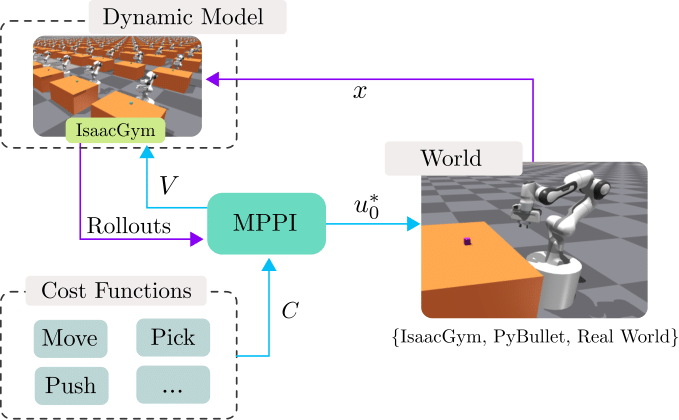
Sampling-based Model Predictive Control Leveraging Parallelizable Physics Simulations
In IEEE Robotics and Automation Letters (RA-L), 2025.
ROME: Robust Multi-Modal Density Estimator
In 33rd International Joint Conference on Artificial Intelligence (IJCAI), 2024.
TrajFlow: Learning Distributions over Trajectories for Human Behavior Prediction
In IEEE Intelligent Vehicles Symposium (IV), 2024.
Multi-Modal MPPI and Active Inference for Reactive Task and Motion Planning
In IEEE Robotics and Automation Letters (RA-L), 2024.
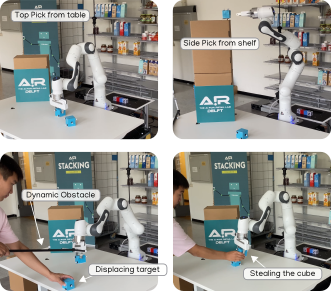
RACP: Risk-Aware Contingency Planning with Multi-Modal Predictions
In IEEE Transactions on Intelligent Vehicles (T-IV), 2024.
Biased-MPPI: Informing Sampling-Based Model Predictive Control by Fusing Ancillary Controllers
In IEEE Robotics and Automation Letters (RA-L), 2024.
Interaction-Aware Sampling-Based MPC with Learned Local Goal Predictions
In Proc. IEEE International Symposium on Multi-Robot and Multi-Agent Systems, 2023.
TrajFlow: Learning the Distribution over Trajectories
In 5th Workshop on Long-term Human Motion Prediction at IEEE Int. Conf. on Robotics and Automation (ICRA), 2023.
Probabilistic Risk Assessment for Chance-Constrained Collision Avoidance in Uncertain Dynamic Environments
In IEEE International Conference on Robotics and Automation (ICRA), 2023.
Sampling-Based MPC Using a GPU-parallelizable Physics Simulator as Dynamic Model: an Open Source Implementation with IsaacGym
In Embracing Contacts Workshop at IEEE Int. Conf. on Robotics and Automation (ICRA), 2023.
Multi-Agent Path Integral Control for Interaction-Aware Motion Planning in Urban Canals
In IEEE Int. Conf. on Robotics and Automation (ICRA), 2023.
Visually-Guided Motion Planning for Autonomous Driving from Interactive Demonstrations
In IFAC Engineering Applications of Artificial Intelligence Journal, 2022.
Regulations Aware Motion Planning for Autonomous Surface Vessels in Urban Canals
In Proc. IEEE Int. Conf. on Robotics and Automation (ICRA), 2022.
Learning Interaction-Aware Guidance for Trajectory Optimization in Dense Traffic Scenarios
In IEEE Transactions on Intelligent Transportation Systems (T-ITS), 2022.